

geopavlakos/hamer. Each hand comes back with 2D joints on the image and 3D joints in meters, so you can measure the hand itself, not only its picture. This guide draws each hand on a 4 s clip of hands tying a box, and detects a pinch from the 3D gap between thumb and index finger.
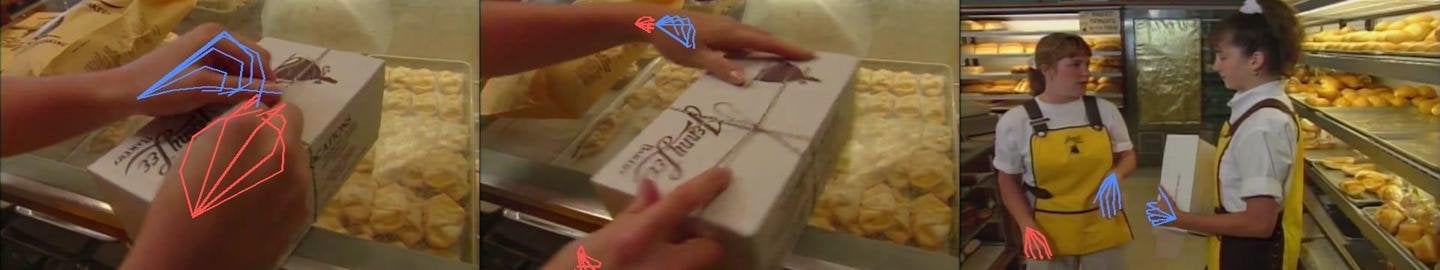
Frames 9, 17, and 26 of the output. Red is a right hand, blue is a left hand.
1. Cut the clip
hamer allows up to 20.
2. Stream and detect a pinch
Python
tracked/, and prints the thumb-to-index gap of every hand. A gap under 3 cm counts as a pinch.
Output
3. Read a hand
Look joints up by name with
kpts_labels, not by a fixed index. The full schema is in world.pose.kpts.
4. The first session after idle
Whenhamer has no running replica, session.create is refused while the Gateway starts one. The session gets an error event, then close 1013:
retry_after seconds, then open a new session. In the first session after start-up, the first 4 reads took about 2 s each and 13 of 32 frames were dropped as busy. Later sessions read every frame. To avoid this at a live event, open a short session a few minutes before you need the model.
Related
Webcam from the Browser
Run a session on a user’s camera.
Masks per Frame
Segment every frame by a text prompt.
Response Types
The
world.pose.kpts schema in JSON, Pydantic, and Zod.Realtime
Session lifecycle, close codes, and billing.